Matlab MiniDrone IIT Kanpur
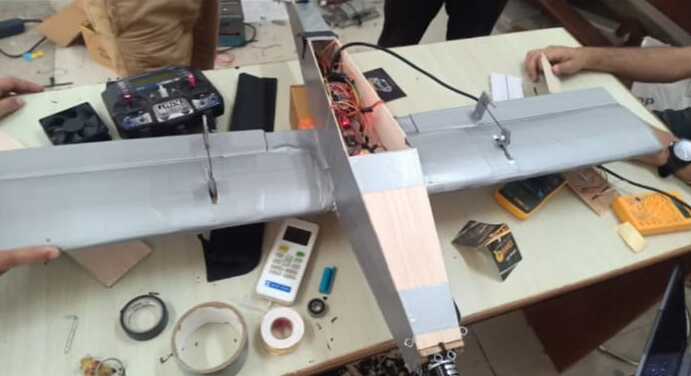
Line Following drone
Members: Dhananjay Goel*, Arnav Kharbanda*, Shreyansh Dubey*, Manan Dangwal*
We developed a line-following drone for the MATLAB Minidrone Competition at IIT Kanpur. Using advanced image processing and control techniques, the drone accurately followed the track, earning us the 2nd runner-up position.
Challenges Faced
- Implementing dilation and erosion techniques for image processing.
- Fine-tuning the PID loop for stable flight and precise path tracking.
- Balancing computational load for real-time performance.